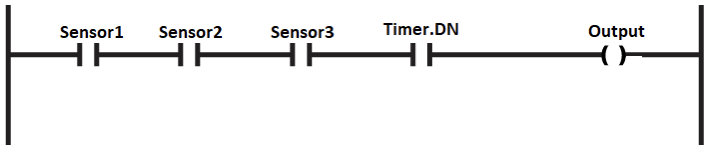
What is a PLC Programmer?

A PLC (Programmable Logic Controller) programmer is a professional in industrial automation.

They design, program, and maintain the rugged computers that control machines and manufacturing systems. 

Their work is key to the smooth and reliable operation of modern industries. This article explains the role, skills, tools, and future of PLC programmers in automation. PLC programmers combine electrical, mechanical, and software knowledge.

They create the logic that automates everything from conveyor systems to chemical processing plants. Their goal is to make machines run efficiently, safely, and predictably.

This article explains how PLC programmers serve as the link between engineering and digital control.

It describes how they use programming logic to transform manual operations into automated processes that enhance productivity and safety.

It also highlights their importance in ensuring that industrial systems communicate effectively, adapt to new technologies, and maintain consistent performance in demanding environments.

The Role of a PLC Programmer

A PLC programmer develops the software that defines how machines behave. They transform operational requirements into automated logic.

This work supports many industries such as automotive, food, packaging, and energy.

Key responsibilities include:

Assessing client requirements

They meet with engineers and plant managers to define how a process should operate. This includes setting sequences, safety logic, and expected machine actions.

Designing and writing programs

They use specialized languages to build control logic that tells the PLC how to react to sensor inputs and control outputs like motors or valves.

Creating schematics

They interpret or produce diagrams that show wiring and component interaction. These documents are vital for programming, troubleshooting, and maintenance.

Testing and commissioning

They debug and test code to confirm that systems work correctly. This often involves on-site startup and validation of performance.

Providing support and maintenance

They handle software and hardware issues after installation. They also modify programs to improve performance or fit new production needs.

How a PLC Works

A PLC operates through a continuous scan cycle, which repeats thousands of times per second. Understanding this process is essential for every programmer.

The cycle includes three main steps:

  1. Read Inputs: The PLC checks all input devices, such as sensors or switches, and stores their status in memory.
  2. Execute Logic: It runs the program line by line to decide what outputs should activate.
  3. Update Outputs: The PLC sends signals to devices like motors or lights according to the results of the logic.

This rapid process creates real-time, reliable control of industrial systems. The figure below indicates a simplified PLC Scan Cycle showing “Read Inputs – Execute Logic – Update Outputs and Loop back.

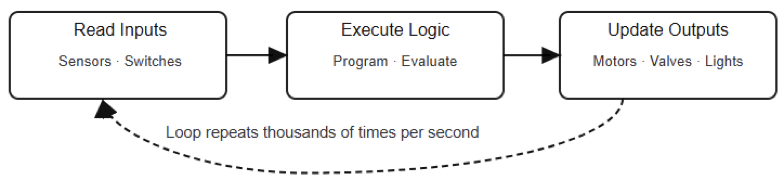
Simplified PLC Scan Cycle

The Languages of PLC Programming

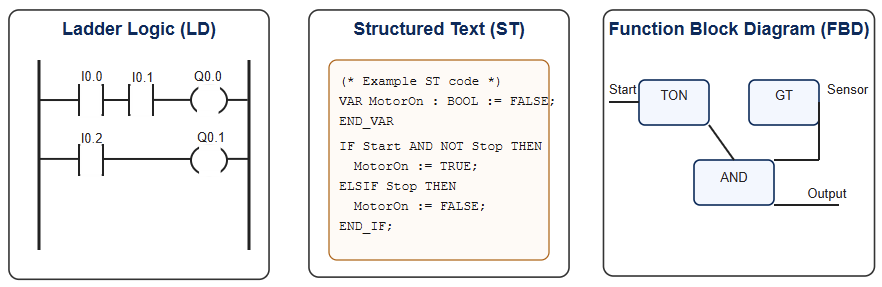
The IEC 61131-3 standard defines five major PLC programming languages. Each one suits different types of applications.

While Ladder Logic remains the most familiar, others are becoming more common as systems grow more complex.

The five standard languages are:

Ladder Logic (LD)

A visual, easy-to-read language that looks like relay circuits. It is popular among electricians and ideal for sequential control.

Structured Text (ST)

A high-level text language similar to C or Pascal, good for math and data handling.

Function Block Diagram (FBD)

A graphical language using blocks connected by lines to represent signal flow. It’s often used in process industries.

Instruction List (IL)

A low-level, assembly-like language. It is less used today but still useful for optimizing performance.

Sequential Function Chart (SFC)

A graphical method to organize processes into steps and transitions, helpful for machines with defined sequences.

The next figure indicates examples of PLC Programming Languages, showing Ladder Logic, Structured Text, and Function Block Diagram.

Essential Skills for a PLC Programmer

A successful PLC programmer needs both technical and soft skills.

Technical skills include:

  • Strong knowledge of at least one major PLC brand, such as Siemens, Allen-Bradley, or Schneider Electric.
  • The ability to read and design electrical diagrams and understand control systems.
  • Experience with HMI (Human-Machine Interface) and SCADA (Supervisory Control and Data Acquisition) systems for operator interaction and data logging.
  • Familiarity with communication networks like Modbus, Profibus, and Ethernet/IP.
  • Understanding of hardware elements such as CPUs, I/O modules, and power supplies.

Soft skills include:

  • Problem-solving: The ability to detect and fix complex faults quickly.
  • Attention to detail: Even a minor error in logic can stop production.
  • Communication: Clear interaction with engineers, operators, and managers.
  • Adaptability: Staying current with evolving automation tools and techniques.

The Path to Becoming a PLC Programmer

There are several ways to enter this field, combining education and hands-on learning.

  1. Education: A degree or diploma in electrical or mechanical engineering helps. Many technical schools offer automation-focused programs.
  2. Experience: Real-world practice is essential. Internships, co-op training, or personal PLC projects provide valuable exposure.
  3. Certification: Credentials from companies like Rockwell or Siemens enhance credibility.
  4. Continuous learning: The technology evolves rapidly, so keeping up with updates, software tools, and new industry standards is vital.

The Future of PLC Programming

The world of automation is advancing quickly, and PLC programmers are adapting to new trends.

  • Integration with IoT: PLCs are now part of larger networks through the Industrial Internet of Things (IIoT), improving monitoring and control.
  • Industry 4.0: Smart factories depend on connected PLCs that enable autonomous decision-making.
  • Cybersecurity: With greater connectivity comes the need for stronger protection against cyber threats.
  • Artificial Intelligence and Machine Learning: These technologies will improve predictive maintenance and product quality.
  • Wireless communication: Reduces wiring and increases flexibility in system design.
  • User-friendly interfaces: Modern tools make programming more intuitive for engineers of different backgrounds.

Key Takeaways: What is a PLC Programmer?

This article explored PLC programmers as the driving force behind modern automation.

It examined their crucial role in designing, coding, and maintaining control systems that keep industrial processes running smoothly. 

By integrating engineering principles with advanced software, PLC programmers ensure that automated operations remain efficient, adaptable, and safe. Hence, the work of a PLC programmer is essential to modern industry. 

They convert operational needs into logical instructions that control automation systems with accuracy and safety.

Their mastery of programming languages and new technologies keeps production efficient and reliable.

As factories evolve toward smarter, connected systems, the role of PLC programmers continues to grow in importance.

They are the unseen force behind every automated process, ensuring precision, safety, and progress.

This article explored the key functions, tools, and future trends shaping the profession of PLC programming.

FAQ: What is a PLC Programmer?

What does a PLC Programmer do?

They design, write, test, and maintain software for programmable logic controllers in industrial settings. 

What skills are needed to be a PLC Programmer?

Technical: programming languages like Ladder Logic, Structured Text; electrical/control systems; safety and hardware knowledge.
Soft: problem-solving, detail orientation, communication, adaptability. 

What kind of education or training is required?

Often a degree or diploma in electrical, mechanical, automation, or related engineering field. Vocational training and PLC-specific certifications help.

Where do PLC Programmers work?

Factories, plants, industrial automation firms, system integrators. Also, in sectors like food & beverage, pharmaceuticals, energy, water treatment. 

Why are PLC Programmers important?

They automate processes, reduce human error, ensure safety, improve efficiency, reduce downtime. 

What tools/software do they use?

PLC programming software (Siemens STEP 7, Allen-Bradley RSLogix etc.), simulation tools, diagnostic and communication modules. 

How does one advance in this career?

Gain experience, take on larger and more complex projects, get certified, stay updated with new technologies like Industry 4.0, IoT. 

PLCs vs DCS vs SCADA: Key Differences, Advantages, and Applications Explained

Industrial automation relies on various control systems that help industries manage complex processes, equipment, and machinery efficiently. Among the most widely used are Programmable Logic Controllers (PLCs), Distributed Control Systems (DCS), and Supervisory Control and Data Acquisition (SCADA) systems. 

These technologies share the common goal of enhancing productivity, reliability, and safety within industrial operations. However, they differ in terms of design, functionality, and application scale. 

Understanding these distinctions is essential for selecting the right system for a specific process.

This article explores the main characteristics of each system, their advantages, and how they integrate to form a unified automation strategy in modern industrial environments.

What is a PLC?

A Programmable Logic Controller (PLC) is a digital industrial computer used for specific control tasks.

It is designed for reliability and to replace old relay-based systems. A PLC uses memory to store instructions that perform logic, timing, and sequencing functions.

PLC architecture

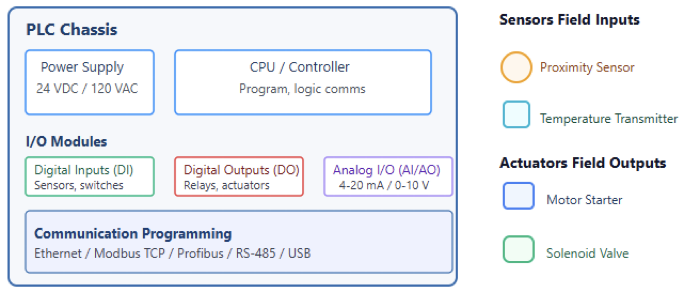
A typical PLC has a modular design. It includes a power supply, a CPU (Central Processing Unit), and input/output (I/O) modules (See Figure).

CPU

The CPU is the main processor. It interprets input signals and runs the control program.

I/O modules

These connect the PLC to the field. Inputs read sensors or switches, while outputs control actuators, motors, or valves.

Programming software

PLCs are programmed with specialized software using languages like ladder logic, function block diagrams or structured text.

Key characteristics of PLCs

  • Discrete control: Best for on/off and repetitive actions, like assembly lines or packaging systems.
  • High speed: Provides quick and predictable control cycles.
  • Local control: Usually manages one machine or process at a time.
  • Cost-effective: Ideal for small-scale control applications.

Advantages and disadvantages of PLCs

Advantages

  • Fast and deterministic control for critical tasks.
  • Durable and reliable in industrial environments.
  • Economical for small to medium systems.
  • Easy to program and troubleshoot.

Disadvantages

  • Limited scalability for very large processes.
  • Becomes harder to manage when many PLCs are networked together.
  • Less redundancy compared to DCS.

What is a DCS?

A Distributed Control System (DCS) is a complete control solution for large and continuous processes in one facility.

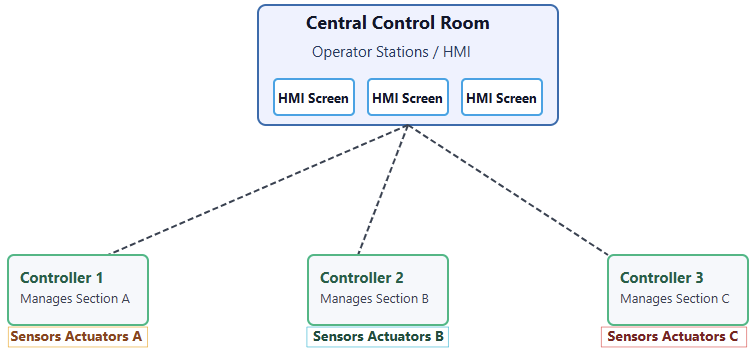
It uses many local controllers connected through a network, all supervised from a central control room.

DCS architecture

A DCS uses a distributed architecture to improve reliability and local control.

Controllers

Several intelligent controllers are placed near the process equipment. Each controls a specific loop or area and often includes redundancy.

Control network

A strong, often redundant communication network links controllers to operator stations.

Operator stations

Human-Machine Interfaces (HMIs) in the control room allow operators to monitor and adjust plant operations.

Key characteristics of a DCS

Continuous process control

Ideal for industries such as oil refining, chemicals, or power generation.

Centralized management

Even though control is distributed, supervision is handled from one point.

High reliability

Built with redundancy to ensure continuous operation.

Integrated features

Includes advanced control, trending, and alarm management tools.

Advantages and disadvantages of DCS

Advantages

  • Perfect for large, complex continuous operations.
  • Highly reliable and fault tolerant due to distributed structure.
  • Centralized monitoring of the entire process.
  • Pre-engineered and integrated, saving setup time.

Disadvantages

  • May respond slower than PLCs in high-speed tasks.
  • Expensive to install and maintain.
  • Proprietary systems may limit compatibility with other equipment.

What is SCADA?

Supervisory Control and Data Acquisition (SCADA) is a software based system for supervising and controlling processes across wide geographic areas.

It gathers data from remote sites and provides operators with a central interface for monitoring and control.

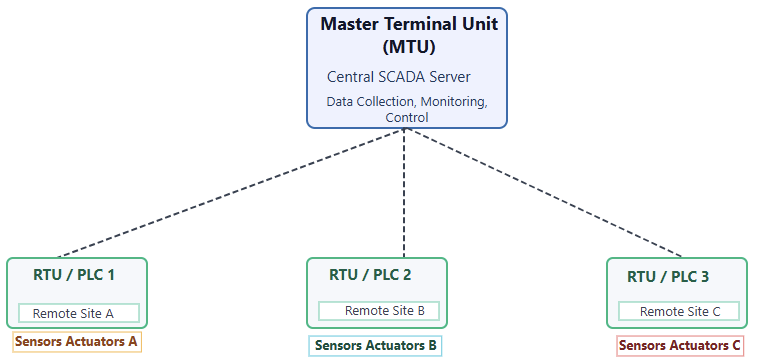
SCADA architecture

A SCADA system has several main parts:

Remote Terminal Units (RTUs) or PLCs

Located at remote sites to collect field data and execute local control.

Master Terminal Unit (MTU)

The central computer or server that communicates with RTUs/PLCs, gathering data and sending commands.

HMI

The graphical interface that shows real-time data, alarms, and allows operator control.

Communication network

Connects the MTU and remote sites using radio, cellular, or internet links.

Key characteristics of SCADA

Supervisory control

Offers an overview of the entire operation, supporting decision making.

Data acquisition

Focused on collecting and storing data for reports and analysis.

Geographically dispersed

Ideal for systems like power grids , water supply or pipelines.

Event-driven

Responds to specific events rather than continuous scanning.

Advantages and disadvantages of SCADA

Advantages:

  • Scalable to monitor large, distributed systems.
  • Compatible with many hardware and communication standards.
  • Strong data logging and reporting abilities.
  • Continues functioning even with unstable connections.

Disadvantages:

  • Supervisory control can introduce slight time delays.
  • Vulnerable to cyber threats due to network dependence.
  • Complex setup with varied hardware and software.

How PLC, DCS, and SCADA work together

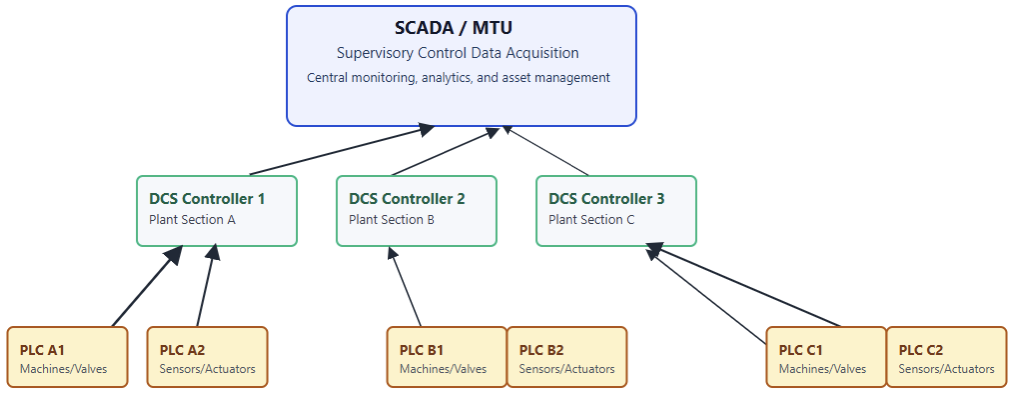
In modern plants, these systems are usually integrated instead of working separately. Together they create a multilayered automation structure.

Bottom layer (PLC)

Handles local, fast, and repetitive control for motors, valves, and pumps.

Middle layer (DCS)

Manages coordinated control for continuous processes, often integrating PLCs into its network for better supervision.

Top layer (SCADA)

Provides supervisory monitoring and data acquisition from the DCS and remote PLCs or RTUs. It allows centralized visualization, data analysis, and remote control.

Choosing the right system

Selecting the proper system depends on the process requirements, scale and budget.

Discrete manufacturing

A single PLC or network of PLCs is usually enough and cost efficient.

Continuous, complex processes

DCS suits these environments best because of its high reliability and integrated functions.

Remote, spread-out operations

SCADA is ideal for long distance systems needing centralized monitoring.

Hybrid systems

Many industries combine all three, using PLCs for equipment control, DCS for process coordination, and SCADA for overall supervision. This hybrid setup delivers complete visibility and control.

The Future of PLC + DCS + SCADA

Over time, the differences between PLC, DCS, and SCADA have become less strict. Modern PLCs are more powerful, while DCS and SCADA have become more open and network compatible.

The future points toward increased integration and smarter connectivity.

Increased integration

Data sharing between all layers is becoming standard. This improves transparency and decision making.

Industrial Internet of Things (IIoT)

The IIoT connects more sensors and systems, generating massive data streams for real-time analysis.

Cloud-based systems

Cloud computing allows scalable and flexible SCADA platforms that can be accessed from anywhere.

Cybersecurity

As connectivity grows, protecting networks from attacks becomes a major priority. Strong encryption, access control, and regular updates are now essential.

Key Takeways: PLCs vs DCS vs SCADA

This article introduced the main characteristics of PLCs, DCS, and SCADA. It further explained, their advantages and how they integrate to form a unified automation strategy in modern industrial environments.

From the discussion, it is clear that the PLCs, DCS, and SCADA form the foundation of industrial automation.

Each has its role and strengths. PLCs provide fast, local control for individual machines.

DCS manages complex and continuous operations with high reliability. SCADA offers wide-area supervision and detailed data analysis.

By understanding how they differ and complement each other helps industries build strong automation strategies. 

This increases productivity, efficiency, and safety. The best choice depends on the type of process, scale, and available resources.

In many cases, the optimal approach is a combination of the three, using each system where it performs best.

As technology advances, integration between PLCs, DCS, and SCADA will become seamless.

This will enable industries to achieve real-time data visibility, improved decision making and smarter control systems for the future of automation.

FAQ: PLCs vs DCS vs SCADA

What does each of PLC, DCS, and SCADA stand for, and what is their basic role?

PLC

Programmable Logic Controller. It’s a rugged digital device used for local, real-time control tasks, reading inputs from field devices, executing logic, and sending outputs to actuators.

DCS

Distributed Control System. It manages large, continuous or batch processes across a plant, using many controllers distributed physically in the plant, with centralized supervisory control and integration. 

SCADA

Supervisory Control and Data Acquisition. It’s more about gathering data from remote or dispersed field devices, providing monitoring and high-level oversight via graphical interfaces and alarms rather than controlling every part of the process directly. 

When is a PLC system sufficient, and when might a DCS be better?

A PLC is often enough if you need control of discrete operations or smaller machines (on/off, sequencing) and fast response times.

  • A DCS is more suitable when you have large, continuous or batch process requirements (e.g., chemical plants, oil & gas, power generation), many control loops, and you need high reliability, redundancy, and process synchronization. 

How is SCADA different from PLCs and DCS in terms of control vs monitoring?

  • SCADA focuses on monitoring, data acquisition, event logging, visualization, and remote supervision. It does some control (via RTUs or PLCs), but its central role is not executing high-speed control loops. 
  • PLCs are about executing control logic in real time. DCS also provides control but adds more integrated, plant-wide, continuous control loops plus supervisory features. 

What are the differences in architecture, network, and redundancy among PLC, DCS, and SCADA?

  • PLC systems are typically localized, modular; communication may be simpler or more limited; redundancy is possible but often less built-in.
  • DCS uses distributed controllers physically spread out, with redundant communication networks, redundant hardware (controllers, I/O, networks), strong integration among components.
  • SCADA must deal with geographically dispersed sites; networks may be less reliable; design usually includes strategies to cope with communication delays or failures; redundancy can be present, especially in server or communication paths.

What are typical applications (industries or use-cases) for each system?

  • PLC: Machine control, robotics, packaging lines, discrete manufacturing.
  • DCS: Continuous process plants (chemical, oil refining, power generation, large scale batch processes) requiring many control loops and high availability.
  • SCADA: Utilities (water/wastewater, electricity), pipelines, transport networks, remote monitoring and control over large distances. 

What are trade-offs or disadvantages of each?

  • PLC: Lower cost, fast, simple for discrete tasks; but less suited to large continuous systems, may lack redundancy and advanced central monitoring. 
  • DCS: More expensive, may use proprietary protocols, less flexible (vendor lock-in), possibly slower response for discrete/high-speed logic than specialized PLCs.
  • SCADA: Latency or delays in control because supervisory; dependency on communication infrastructure; possible vulnerabilities in remote or networked setups; complexity in integrating diverse hardware/protocols.

Can these systems be combined or work together? How?

Yes. Many systems use PLCs at the field/machine level, DCS for larger coordinated control of continuous or batch processes across the plant, and SCADA for supervisory oversight, remote monitoring, analytics, and global operators’ view. 

For example, PLCs may handle discrete machine control; DCS handles analog loops, process coordination; SCADA gathers data from both PLCs and DCS, provides alarm and reporting, and allows remote control. 

Are PLCs and DCS converging?

Yes. Modern PLCs have adopted features once mostly in DCS: better networking, greater redundancy, advanced control blocks.

Conversely, DCS systems are adopting more open communications protocols and modular architectures that resemble PLC-based installations. 

What should be considered when choosing between PLC, DCS, or SCADA for a new industrial project?

Some key factors:

  • Process type: discrete, continuous, or batch.
  • Scale and complexity: how many control loops, devices, geographical spread.
  • Need for redundancy, reliability, downtime cost.
  • Speed and determinism of control tasks (how fast response needed).
  • Budget, both initial cost and maintenance.
  • Integration needs: with other equipment, with data systems, possible remote sites.
  • Communication infrastructure and network reliability. 

PLC PID Control Explained Simply

A PID controller is the brain behind many automated processes. It helps a system automatically maintain a specific target, or “setpoint,” with great accuracy.

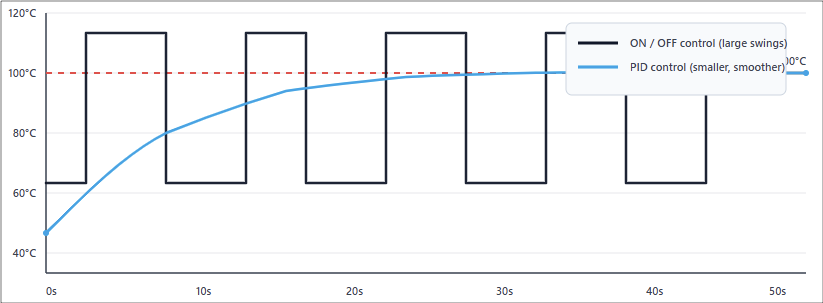
Unlike a simple ON/OFF switch, which can cause large swings, a PID uses a clever formula to make smooth, precise adjustments.

 In industrial settings, PID control is often run by a Programmable Logic Controller (PLC).

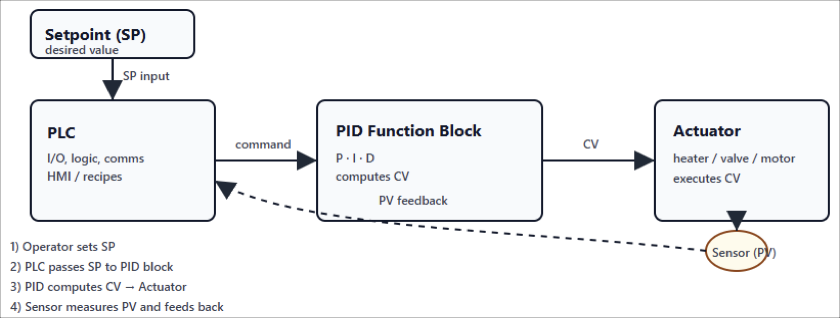
The PLC executes the PID algorithm and translates its calculations into commands that control machinery. 

This article will explain the core concepts of PLC PID control. It will break down how the “Proportional,” “Integral,” and “Derivative” terms work together to create a feedback loop that achieves and maintains a setpoint. 

We will explore the common challenge of “tuning” and provide practical examples of how PLC PID control is used in the real world. 

The Problem with Simple Control

Let’s begin with a relatable example: controlling the temperature in an oven. In the simplest system, this works like a light switch:

  • The oven’s setpoint is the desired temperature.
  • A sensor measures the current, actual temperature.
  • If the temperature is too low, the controller turns the heater ON.
  • If the temperature is too high, the controller turns the heater OFF.

This strategy is known as ON/OFF control. It is simple, but it has a big problem. It causes constant swings above and below the setpoint. The heater overshoots, then shuts off, then undershoots, and the cycle repeats.

This leads to inefficiency. The equipment experiences more stress and wears out faster.

For processes where high precision matters, like chemical reactions or semiconductor manufacturing, this is unacceptable.

That is why industries use PID control. It takes a smarter approach, one that reduces oscillations and provides smoother, more accurate control.

The Foundation: The Feedback Loop

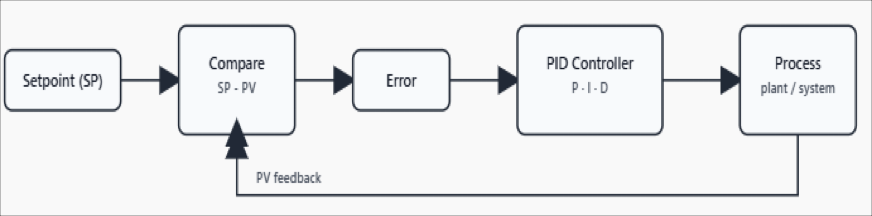
At the heart of PID control lies a feedback loop. This is the continuous cycle where the system checks itself, compares values, and makes corrections.

There are four key parts to understand:

Setpoint (SP)

The target value. For example, keeping an oven at exactly 100 °C.

Process Variable (PV)

The actual measured value. This comes from a sensor, like a thermometer.

Error (E)

The difference between the setpoint and the process variable. Formula: E = SP – PV.

Control Variable (CV)

The output signal calculated by the PID algorithm and sent by the PLC to the equipment. For an oven, this could be the amount of power delivered to the heater.

The goal of the PID controller is simple in theory: make the error as close to zero as possible.

But in practice, achieving that balance requires the three components: P, I, and D — to work together. Each has a unique role in shaping how the system reacts.

The P, I, and D Explained

Proportional Term (P) – Reacting to the Present

The Proportional term is the most direct part of the equation. It creates a correction that is proportional to the size of the error.

  • If the error is big, the correction is big.
  • If the error is small, the correction is small.
  • As you approach the setpoint, the adjustment becomes gentler.

You can compare it to pressing the gas pedal in a car. If you are far from your target speed, you press harder. As you get close, you ease off.

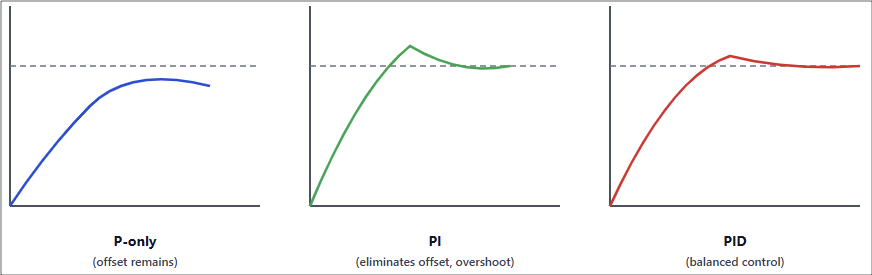
But proportional control has a weakness. It often leaves a small, constant error known as offset.

This happens because the controller always needs some error to generate an output. The system gets close to the setpoint, but not exactly there.

Integral Term (I) – Learning from the Past

The Integral term solves the offset problem. It looks at the error not just in the present, but over time.

  • It adds up the error history, essentially remembering how long and how large the error has been.
  • If a small error keeps occurring, the integral term grows until it pushes the system to eliminate it completely.
  • Over time, this ensures the process reaches the exact setpoint.

But there is a catch. If the integral is set too strong, the system can overshoot. This means it goes past the setpoint and swings back, sometimes several times.

A related issue is integral windup, where the integral keeps building even when the actuator is already at maximum output.

Derivative Term (D) – Predicting the Future

The Derivative term acts like a predictor. It looks at how quickly the error is changing and estimates where it is headed.

  • If the error is rising fast, the derivative provides a damping force to slow it down.
  • This prevents overshoot and improves stability.
  • It is especially useful in fast-moving processes, like speed control in motors.

However, derivative control is sensitive to noise. If the sensor signal is noisy, the derivative will amplify it, causing jerky outputs. For this reason, many industries use just PI control instead of full PID.

The Role of the PLC

In the past, engineers had to build dedicated hardware for PID control. Today, modern PLCs make it much easier. They come with built-in PID function blocks.

Integration

A PLC connects the sensor inputs (PV) and the actuators that carry out the control variable (CV).

Programming

In the PLC software, you simply insert a PID block, connect the PV and SP signals, and link the output to the device.

Tuning

The PLC stores the gain values for P, I, and D. You can adjust them directly through the interface.

This makes PID implementation more accessible. Even technicians who are not control theory experts can use PLC software to set up and tune loops.

Tuning Your PID Loop

Tuning is the art of adjusting the P, I, and D parameters until the system behaves well. The perfect settings depend on the process.

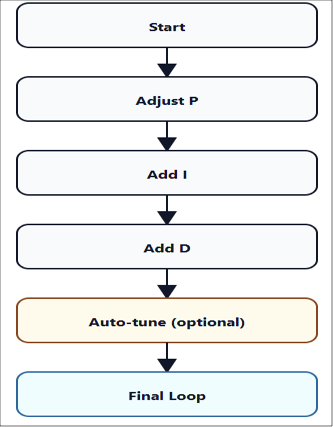
Start with P

Begin with only proportional control. Increase the gain until the system starts to oscillate, then reduce it to about half.

Add I

Introduce a small integral value. This removes steady-state error. Increase it slowly until the error disappears without causing big swings.

Add D (if necessary)

If your process reacts quickly or tends to overshoot, add a little derivative action for damping.

Auto-tune

Many modern PLCs have an auto-tune feature. The system runs a test, observes behavior, and automatically suggests PID values.

Good tuning balances speed, accuracy, and stability. Poor tuning causes overshoot, oscillations, or sluggish response.

Real-World Examples

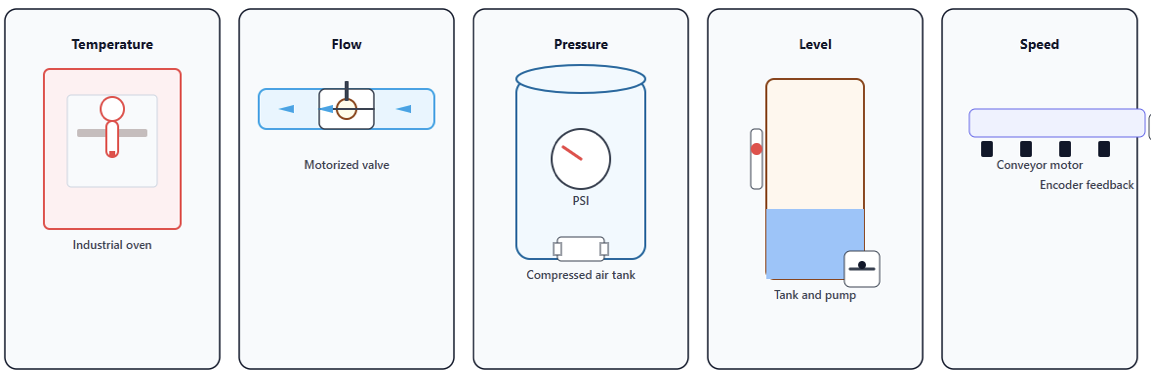
Let’s look at where PID control in PLCs is actually used:

Temperature Control

In an industrial oven, the PLC reads temperature from a thermocouple (PV). It compares it to the setpoint (SP). The PID output adjusts gas or electric heaters. The result is precise, stable heating.

Flow Control

In pipelines, a PLC measures flow rate with a flow meter. The PID loop adjusts a motorized valve. This keeps the liquid flowing at the correct rate.

Pressure Control

In compressed air systems, a PID loop keeps tank pressure constant. It does this by controlling a compressor or a pressure valve.

Level Control

In tanks, the PLC monitors liquid level with a sensor. The PID loop controls pumps or valves to maintain the level.

Speed Control

Conveyor belts often require consistent speeds. A PID loop uses feedback from an encoder and adjusts the motor drive to hold steady speed.

Key Takeaways: PLC PID Control Explained Simply

PLC PID control is one of the most important tools in industrial automation. It is flexible, powerful, and surprisingly simple once you understand the basics.

Instead of crude ON/OFF control, a PID controller gives you three smart strategies — Proportional, Integral, and Derivative.

Together, they make the system respond not only to the present error, but also to past trends and future predictions.

A well-tuned PID loop can handle small drifts, sudden disturbances, and long-term stability.

Thanks to modern PLCs, implementing PID is easier than ever. Built-in blocks and auto-tuning make advanced control accessible even for non-specialists.

The payoff is huge: stable processes, better quality products, reduced wear on equipment, and more efficient energy use.

With a strong grasp of PID basics, you can start unlocking the full power of your automated systems.

FAQ: PLC PID Control Explained Simply

What does “PID” stand for in a PID controller?

PID stands for Proportional, Integral, and Derivative. These are the three control actions or terms that combine to determine the controller’s output based on how far, how long, and how fast the system error is changing.

What is a PID controller’s basic purpose?

A PID controller continuously compares a process variable (PV) with a desired setpoint (SP).

It then calculates an error (SP − PV), and uses the P, I, and D terms to adjust the output in order to reduce that error. The goal is to bring the process variable to the setpoint and keep it stable.

What does each term (P, I, D) do?

Proportional (P): Reacts to the current error. Larger error → larger correction. Helps reduce rise time but can leave a steady-state error.

Integral (I): Accumulates error over time. It addresses steady error or offset that P alone cannot eliminate.

Derivative (D): Looks at the rate at which error is changing. It acts to dampen or slow the controller’s response to prevent overshoot or oscillations. It’s like anticipating what might happen next.

Why is PID tuning important, and what are some common tuning methods?

Tuning means selecting or adjusting the gains (or time constants) of P, I, and D so the controlled process responds nicely (fast, stable, minimal overshoot, minimal steady error).

Without good tuning, the system might oscillate, respond too slowly, or constantly overshoot. 

Common tuning methods include: Manual tuning, by observing system behavior (e.g. increase P until borderline oscillation, then adjust I and D).

Auto-tuning, where the controller itself runs experiments to estimate good gains; Empirical rules like Ziegler-Nichols method.

What is “integral windup”, and how can it be prevented?

Integral windup occurs when the integral term builds up too much error — for example while the output is saturated (at its maximum or minimum limit) and cannot respond further.

When the constraint is removed, this “built up” integral can lead to overshoot or long settling times.

Prevention strategies include: Limiting or bounding the integral term; Using anti-windup logic (e.g. disabling integration when output is saturated or using back-calculation).

Can a PID controller have a simple ON/OFF output?

Yes, though that depends on application. The core PID algorithm usually produces an analog or continuously varying output.

But in some systems, that analog output is converted (via things like PWM or duty cycling) into ON/OFF switching to control physical devices (like heaters) that can’t respond continuously. 

What are the limitations of PID control?

Some limitations include: Sensitivity to noise, especially in the derivative term. Difficulties with non-linear systems or processes whose behavior changes with operating conditions.

Challenges in responding to large or sudden disturbances or changes in setpoint. If the system has long delays (dead time), PID can struggle; Potential overshoot or oscillations if tuning is not done properly. 

What is a “control loop” and what types are there?

A control loop refers to the cycle where the system measures a variable (PV), compares it with the desired value (SP), computes the error, uses a controller to adjust an actuator (CV), and affects the process, which feeds back into PV. This happens continuously.

Types include: Open loop, where no feedback is used — the controller doesn’t see the output; Closed loop, which is what PID control is — feedback is used to adjust continuously. 

How does the derivative term affect stability?

The derivative term adds damping. It helps reduce overshoot and smooth out fast changes.

That improves stability when things are changing rapidly. However, if derivative gain is too large, or if the sensor signal is noisy, it can cause erratic controller output or instability. 

What is “dead time” and how does it impact PID control?

Dead time (or delay) is the time lag between when the controller output changes and when its effect is first observed in the process variable. Long dead times make control harder because the system reacts slowly.

They can degrade performance, cause overshoot or oscillation, or make tuning more difficult. 

When might you use PI control instead of full PID?

PI (Proportional + Integral) control is often enough when the process is slower, or derivative action is not helpful (for example because of sensor noise, or small benefit versus complexity).

Many industrial applications omit the derivative term to simplify control and avoid amplifying noise. 

Dedicated PID devices vs. using a PLC for PID loops — which is better?

It depends on scale and complexity: Dedicated devices (stand-alone PID controllers) are good for simple, localized control (one loop, local HMI), fast deployment, less programming overhead.

PLCs are better when you need multiple loops, integration with other automation logic, data logging, supervising, HMI, alarms, etc.

They offer flexibility, communication, easier maintenance when multiple loops or complexity are involved.

15 Common PLC Programming Mistakes to Avoid

Programmable Logic Controllers (PLCs) sit at the heart of modern industry. They control machines, production lines, and entire plants.

A well-written PLC program can make a factory run smoothly while a poorly written one can cause downtime, safety issues, and costly repairs.

Programming a PLC is not just about making it “work.” It’s about making it reliable, safe, readable, and easy to maintain.

Many beginners, and even experienced programmers, fall into common traps. The good news? Most of these mistakes can be avoided with awareness and good habits.

This article explores the most common PLC programming mistakes. We’ll explain why they happen, what problems they cause, and how to avoid them.

Whether you’re a student, technician, or engineer, these lessons can save you time, stress, and money.

Mistake 1: Poor Documentation

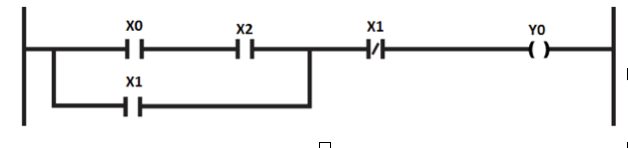
One of the most overlooked parts of PLC programming is documentation. We usually rush to write code and forget to label inputs, outputs, or describe logic.

If you re-open the same program in the future, you will see hundreds of rungs, all with cryptic tags like the one shown in the figure below. You have no idea what they control. Troubleshooting becomes a difficult task.

Problem: ItMakes maintenance slow; Leads to confusion for others (or even yourself); Increases risk of errors when modifying code.

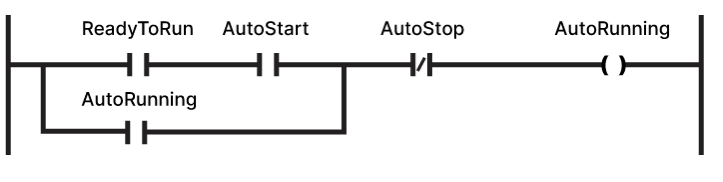
Avoidance: Use clear tag names. Instead of “X0, X1, Y0, Y1” use “ReadyToRun.”, add rung comments to explain what each section does and keep a separate document with I/O lists, wiring diagrams, and descriptions. See the figure below:


Takeaway: Good documentation is like leaving a roadmap for the next person and sometimes, that “next person” is you.

Mistake 2: Overcomplicating the Code

“The more complex the code, the smarter it looks”, this is a belief to some programmers. The truth is the opposite. Overcomplicated logic is harder to read, harder to debug, and more prone to failure.

Problem: Increases programming time, makes troubleshooting difficult and confuses technicians who may not be programmers.

Example:
Instead of using three rungs with simple logic, someone nests ten different conditions into one rung. The machine may still work, but no one else understands how.


Avoidance: Keep logic simple, one rung should handle one clear task, break large processes into smaller sections and use function blocks or subroutines for repeated logic.